roborazzi
Make JVM Android integration test visible 🤖📸
Safety scan
A static text scan, not a guarantee. Select the badge to see what was scanned and every finding.
Check it deeper on your machine
It has changed since its scan on 11 Nov 2026.
As a Claude Code plugin, install it and then ask Claude Code:
/plugin marketplace add keithmackay/mackayi/plugin install scanskillsafety@mackayiDo a deep scan of https://github.com/takahirom/roborazzi with scanskillsafety
Or from a terminal, clone it and run it:
git clone https://github.com/keithmackay/scanskillsafety-skill ~/.claude/skills/scanskillsafetynode ~/.claude/skills/scanskillsafety/cli.cjs --deep 'https://github.com/takahirom/roborazzi'
It checks the exact commit: every file, its packages against OSV (api.osv.dev), how it compares with this page's scan (findsafeskills.com receives the repository's address), and, if you agree, Claude reading every file with your own Claude subscription. It never runs the code.
Badge for your README

Markdown
[](/listings/takahirom--roborazzi)HTML
<a href="/listings/takahirom--roborazzi"><img src="/api/listings/takahirom--roborazzi/badge.svg" alt="findsafeskills safety rating" /></a>Install
Install instructions from the README
As written by the repo's author. findsafeskills has not verified these steps.
Roborazzi is available on maven central.
This plugin simply creates Gradle tasks record, verify, compare and passes the configuration to the test.
**build.gradle.kts** <table> <tr><td>plugins</td><td>buildscript</td></tr> <tr><td>
Define plugin in root build.gradle.kts
plugins {
  ...
  id("io.github.takahirom.roborazzi") version "[version]" apply false
}Apply plugin in module build.gradle.kts
plugins {
  ...
  id("io.github.takahirom.roborazzi")
}</td><td>
root build.gradle.kts
buildscript {
  dependencies {
    ...
    classpath("io.github.takahirom.roborazzi:roborazzi-gradle-plugin:[version]")
  }
}module build.gradle.kts
plugins {
    ...
    id("io.github.takahirom.roborazzi")
}</td></tr>
</table>
<details> <summary>build.gradle version</summary> <table> <tr><td>plugins</td><td>buildscript</td></tr> <tr><td>
Define plugin in root build.gradle
plugins {
  ...
  id "io.github.takahirom.roborazzi" version "[version]" apply false
}Apply plugin in module build.gradle
plugins {
  ...
  id 'io.github.takahirom.roborazzi'
}</td><td>
root build.gradle
buildscript {
  dependencies {
    ...
    classpath "io.github.takahirom.roborazzi:roborazzi-gradle-plugin:[version]"
  }
}module build.gradle
apply plugin: "io.github.takahirom.roborazzi"
</td></tr>
</table> </details>
Add dependencies
| Description | Dependencies | |-----------------|--------------------------------------------------------------------------------------| | Core functions | `testImplementation("io.github.takahirom.roborazzi:roborazzi:[version]")` | | Jetpack Compose | `testImplementation("io.github.takahirom.roborazzi:roborazzi-compose:[version]")` | | JUnit rules | `testImplementation("io.github.takahirom.roborazzi:roborazzi-junit-rule:[version]")` |
Run tasks
<table> <tr> <td> Use Roborazzi task </td> <td> Use default unit test task </td> <td> Description </td> </tr> <tr> <td>
`./gradlew recordRoborazziDebug`
</td><td>
`./gradlew testDebugUnitTest` after adding `roborazzi.test.record=true` to your gradle.properties file.
or
`./gradlew testDebugUnitTest -Proborazzi.test.record=true`
</td><td>
Record a screenshot Default output directory is `build/outputs/roborazzi` You can check a report under `build/reports/roborazzi/index.html`
</td> </tr> <tr> <td>
`./gradlew compareRoborazziDebug`
</td><td>
`./gradlew testDebugUnitTest` after adding `roborazzi.test.compare=true` to your gradle.properties file.
or
`./gradlew testDebugUnitTest -Proborazzi.test.compare=true`
</td><td>
Review changes made to an image. This action will compare the current image with the saved one, generating a comparison image labeled as `[original]_compare.png`. It also produces a JSON file containing the diff information, which can be found under `build/test-results/roborazzi`.
</td> </tr> <tr> <td>
`./gradlew verifyRoborazziDebug`
</td><td>
`./gradlew testDebugUnitTest` after adding `roborazzi.test.verify=true` to your gradle.properties file.
or
`./gradlew testDebugUnitTest -Proborazzi.test.verify=true`
</td><td>
Validate changes made to an image. If there is any difference between the current image and the saved one, the test will fail.
</td> </tr> <tr> <td>
`./gradlew verifyAndRecordRoborazziDebug`
</td><td>
`./gradlew testDebugUnitTest` after adding `roborazzi.test.verify=true` and `roborazzi.test.record=true` to your gradle.properties file.
or
`./gradlew testDebugUnitTest -Proborazzi.test.verify=true -Proborazzi.test.record=true`
</td><td>
This task will first verify the images and, if differences are detected, it will record a new baseline.
</td> </tr>
<tr> <td>
`./gradlew clearRoborazziDebug`
</td><td>
This is not a test task.
</td><td>
Note: This is an experimental task.
What was scanned
The files the safety scan read, as written by the repository's author and shown as plain text. Lines with a finding are marked.
README.md · README · 2,236 lines
View this file on GitHub (read at the repository's current version: the scan did not record which commit it read)
This file has changed since it was scanned, so this is not exactly the text that was scanned, and no line is marked. The findings are listed with the safety scan above.
- <!-- Generated by ./gradlew generateReadme. Do not edit this file. -->
- <!-- topic_top -->
- <!-- Generated by docs/topics/top.md. Do not edit this file. -->
- # Roborazzi
- **Make JVM Android Integration Test Visible**
- ## Roborazzi now supports [Robolectric Native Graphics (RNG)](https://github.com/robolectric/robolectric/releases/tag/robolectric-4.10) and enables screenshot testing.📣
- ## Why Choose Roborazzi?
- ### Why is screenshot testing important?
- Screenshot testing is key to validate your app's appearance and functionality. It efficiently
- detects visual issues and tests the app as users would use it, making it easier to spot problems.
- It's quicker than writing many assert statements, ensuring your app looks right and behaves
- correctly.
- ### What are JVM tests and why test with JVM instead of on Android?
- JVM tests, also known as local tests, are placed in the test/ directory and are run on a developer's
- PC or CI environment. On the other hand, device tests, also known as Instrumentation tests, are
- written in the androidTest/ directory and are run on real devices or emulators. Device testing can
- result in frequent failures due to the device environment, leading to false negatives. These
- failures are often hard to reproduce, making them tough to resolve.
- ### Paparazzi and Roborazzi: A Comparison
- Paparazzi is a great tool for visualizing displays within the JVM. However, it's incompatible with
- Robolectric, which also mocks the Android framework.
- Roborazzi fills this gap. It integrates with Robolectric, allowing tests to run with Hilt and
- interact with components. Essentially, Roborazzi enhances Paparazzi's capabilities, providing a more
- efficient and reliable testing process by capturing screenshots with Robolectric.
- **Leveraging Roborazzi in Test Architecture: An Example**
- <img src="https://github.com/takahirom/roborazzi/assets/1386930/937a96a4-f637-4029-87e1-c1bb94abc8ae" width="320" />
- **Integrating Roborazzi into the Architecture: An Example from DroidKaigi 2023 App**
- In the DroidKaigi 2023 app, Roborazzi was introduced from the early stages of development as part of the architectural design. This integration allowed the team to verify changes throughout the development process. The specific architectural decisions and how they were implemented can be found [README](https://github.com/DroidKaigi/conference-app-2023#screenshot-testing-with-robolectric-native-graphics-rng-and-roborazzi).
- ## Using Roborazzi documentation with AI coding agents
- Roborazzi ships its documentation as an installable [agent skill](https://skills.sh/). Running the
- following command installs the docs into your AI coding agent (Claude Code, Cursor, Codex,
- [Android Studio Agent Mode](https://developer.android.com/studio/gemini/skills), Antigravity,
- Gemini CLI, etc.),
- so the agent can look up Roborazzi setup and usage while working on your project:
- ```bash
- npx skills add takahirom/roborazzi
- ```
- <!-- end -->
- <!-- topic_try_it_out -->
- <!-- Generated by docs/topics/try_it_out.md. Do not edit this file. -->
- # Try it out
- Available on Maven Central.
- ## Add Robolectric
- This is an example of adding Robolectric to your project:
- https://github.com/takahirom/roborazzi-usage-examples/compare/b697...5c12
- This library is dependent on Robolectric. Please see below to add Robolectric.
- https://robolectric.org/getting-started/
- ## Add Roborazzi
- This is an example of adding Roborazzi to your project:
- https://github.com/takahirom/roborazzi-usage-examples/commit/3a02
- To take screenshots, please use Robolectric 4.10 alpha 1 or later and please
- add `@GraphicsMode(GraphicsMode.Mode.NATIVE)` to your test class.
- ```kotlin
- @GraphicsMode(GraphicsMode.Mode.NATIVE)
- ```
- <!-- end -->
- <!-- topic_build_setup -->
- <!-- Generated by docs/topics/build_setup.md. Do not edit this file. -->
- # Build setup
- Roborazzi is available on maven central.
- This plugin simply creates Gradle tasks record, verify, compare and passes the configuration to the
- test.
- **build.gradle.kts**
- <table>
- <tr><td>plugins</td><td>buildscript</td></tr>
- <tr><td>
- Define plugin in root build.gradle.kts
- ```kotlin
- plugins {
- ...
- id("io.github.takahirom.roborazzi") version "[version]" apply false
- }
- ```
- Apply plugin in module build.gradle.kts
- ```kotlin
- plugins {
- ...
- id("io.github.takahirom.roborazzi")
- }
- ```
- </td><td>
- root build.gradle.kts
- ```kotlin
- buildscript {
- dependencies {
- ...
- classpath("io.github.takahirom.roborazzi:roborazzi-gradle-plugin:[version]")
- }
- }
- ```
- module build.gradle.kts
- ```kotlin
- plugins {
- ...
- id("io.github.takahirom.roborazzi")
- }
- ```
- </td></tr>
- </table>
- <details>
- <summary>build.gradle version</summary>
- <table>
- <tr><td>plugins</td><td>buildscript</td></tr>
- <tr><td>
- Define plugin in root build.gradle
- ```groovy
- plugins {
- ...
- id "io.github.takahirom.roborazzi" version "[version]" apply false
- }
- ```
- Apply plugin in module build.gradle
- ```groovy
- plugins {
- ...
- id 'io.github.takahirom.roborazzi'
- }
- ```
- </td><td>
- root build.gradle
- ```groovy
- buildscript {
- dependencies {
- ...
- classpath "io.github.takahirom.roborazzi:roborazzi-gradle-plugin:[version]"
- }
- }
- ```
- module build.gradle
- ```groovy
- apply plugin: "io.github.takahirom.roborazzi"
- ```
- </td></tr>
- </table>
- </details>
- ## Add dependencies
- | Description | Dependencies |
- |-----------------|--------------------------------------------------------------------------------------|
- | Core functions | `testImplementation("io.github.takahirom.roborazzi:roborazzi:[version]")` |
- | Jetpack Compose | `testImplementation("io.github.takahirom.roborazzi:roborazzi-compose:[version]")` |
- | JUnit rules | `testImplementation("io.github.takahirom.roborazzi:roborazzi-junit-rule:[version]")` |
- ## Run tasks
- <table>
- <tr>
- <td> Use Roborazzi task </td> <td> Use default unit test task </td> <td> Description </td>
- </tr>
- <tr>
- <td>
- `./gradlew recordRoborazziDebug`
- </td><td>
- `./gradlew testDebugUnitTest` after adding `roborazzi.test.record=true` to your gradle.properties file.
- or
- `./gradlew testDebugUnitTest -Proborazzi.test.record=true`
- </td><td>
- Record a screenshot
- Default output directory is `build/outputs/roborazzi`
- You can check a report under `build/reports/roborazzi/index.html`
- </td>
- </tr>
- <tr>
- <td>
- `./gradlew compareRoborazziDebug`
- </td><td>
- `./gradlew testDebugUnitTest` after adding `roborazzi.test.compare=true` to your gradle.properties file.
- or
- `./gradlew testDebugUnitTest -Proborazzi.test.compare=true`
- </td><td>
- Review changes made to an image. This action will
- compare the current image with the saved one, generating a comparison image labeled
- as `[original]_compare.png`. It also produces a JSON file containing the diff information, which can
- be found under `build/test-results/roborazzi`.
- </td>
- </tr>
- <tr>
- <td>
- `./gradlew verifyRoborazziDebug`
- </td><td>
- `./gradlew testDebugUnitTest` after adding `roborazzi.test.verify=true` to your gradle.properties file.
- or
- `./gradlew testDebugUnitTest -Proborazzi.test.verify=true`
- </td><td>
- Validate changes made to an image. If there is any difference between the current image and the
- saved one, the test will fail.
- </td>
- </tr>
- <tr>
- <td>
- `./gradlew verifyAndRecordRoborazziDebug`
- </td><td>
- `./gradlew testDebugUnitTest` after adding `roborazzi.test.verify=true` and `roborazzi.test.record=true` to your gradle.properties file.
- or
- `./gradlew testDebugUnitTest -Proborazzi.test.verify=true -Proborazzi.test.record=true`
- </td><td>
- This task will first verify the images and, if differences are detected, it will record a new
- baseline.
- </td>
- </tr>
- <tr>
- <td>
- `./gradlew clearRoborazziDebug`
- </td><td>
- This is not a test task.
- </td><td>
- Note: This is an experimental task.
- This task will clear the saved images. This task also deletes the cached images.
- Please be careful when using this task.
- </td>
- </tr>
- </table>
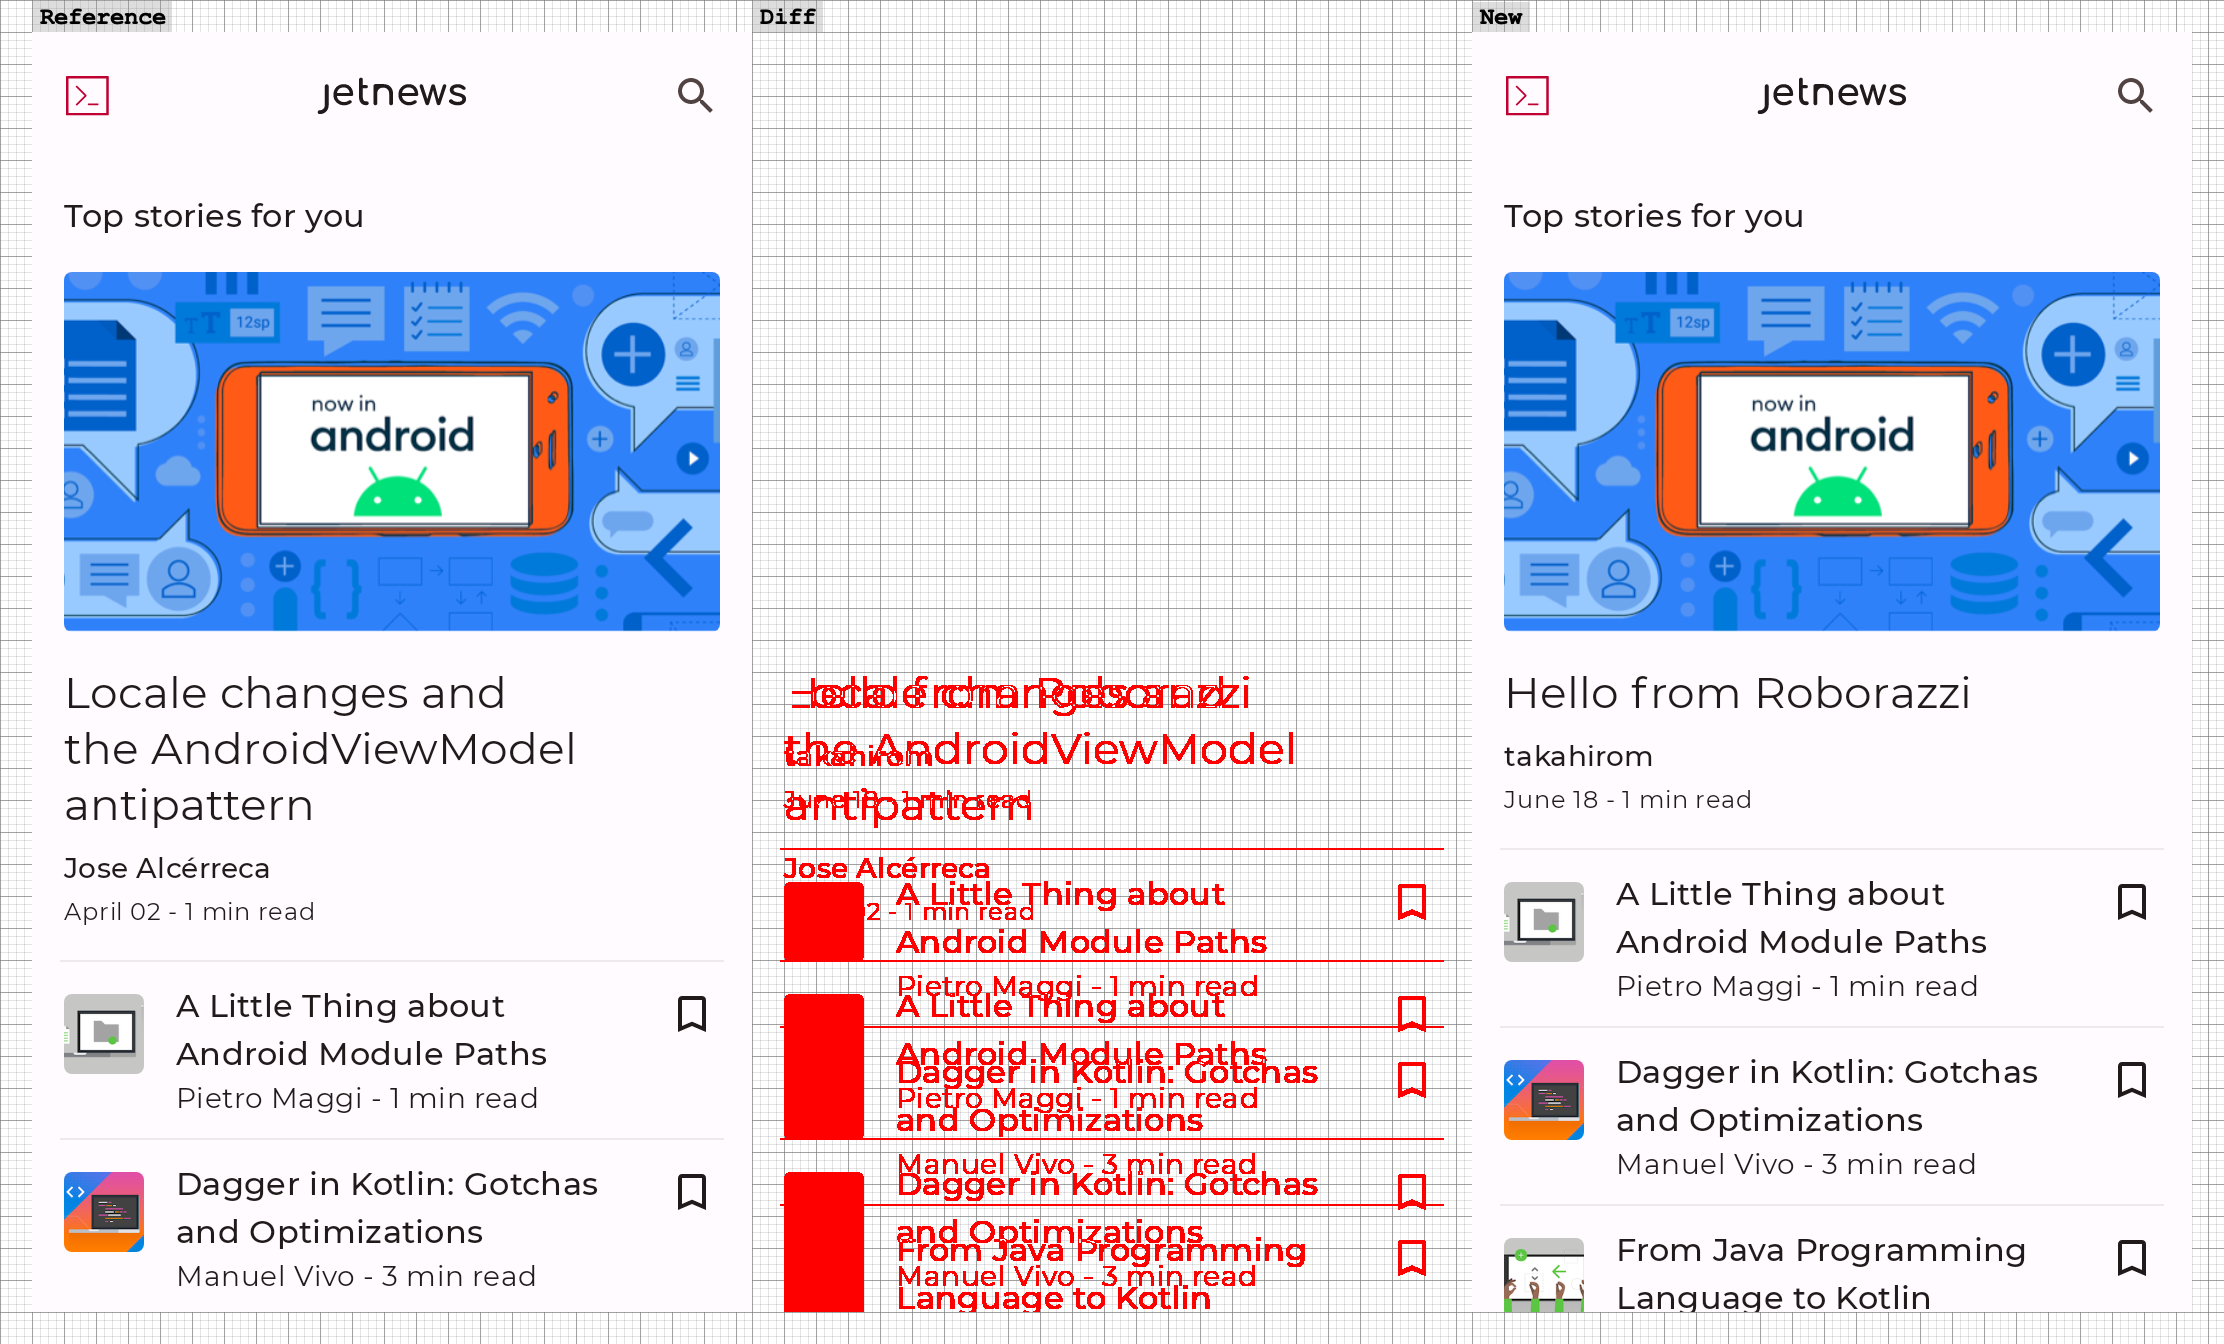
- The comparison image, saved as `[original]_compare.png`, is shown below:
- 
- You can check the test report in `build/reports/roborazzi/index.html`
- <img width="400" alt="image" src="https://github.com/takahirom/roborazzi/assets/1386930/7834a436-1927-438d-8656-61f583ae3f48" />
- This
- uses [JetNew from Compose Samples](https://github.com/android/compose-samples/tree/main/JetNews).
- You can check the pull request introducing Roborazzi to the
- compose-samples [here](https://github.com/takahirom/compose-samples/pull/1/files).
- ## Gradle DSL Options (Optional)
- Roborazzi uses `module/build/outputs/roborazzi` as the default directory for reference images and comparison images. You can customize these paths in your `build.gradle` file:
- ```kotlin
- roborazzi {
- // Directory for reference images
- outputDir.set(file("src/screenshots"))
- // Directory for comparison images (Experimental option)
- compare {
- outputDir.set(file("build/outputs/screenshots_comparison"))
- }
- }
- ```
- > [!NOTE]
- > By default, when you use `captureRoboImage("image.png")`, the image will be saved as `module/image.png`.
- > You can customize the file path strategy for the recorded image. The default strategy is `relativePathFromCurrentDirectory`. If you select `relativePathFromRoborazziContextOutputDirectory`, the file will be saved in the output directory specified by `roborazzi.outputDir`.
- > This can be configured in your `gradle.properties` file:
- >
- > ```properties
- > roborazzi.record.filePathStrategy=relativePathFromRoborazziContextOutputDirectory
- > ```
- ### Separate output directories per variant/target (Experimental)
- By default, every Roborazzi task shares a single output directory (`build/outputs/roborazzi`) and a single intermediate directory (`build/intermediates/roborazzi`). When multiple Roborazzi test tasks run in a single Gradle invocation (for example `check`, or Kotlin Multiplatform's `allTests`), their directory reads and writes can race with each other. On Gradle 9 this can hard-fail with `Cannot access input property 'roborazziImageInput'` (see [#830](https://github.com/takahirom/roborazzi/issues/830)).
- Enabling `separateOutputDirs` gives each task slug its own subdirectory, so the tasks never share a directory:
- ```kotlin
- roborazzi {
- // Experimental
- separateOutputDirs.set(true)
- }
- ```
- The unit of separation is the `recordRoborazzi<Slug>` slug:
- - Android: the variant name, e.g. `build/outputs/roborazzi/debug/`, `build/outputs/roborazzi/release/`.
- - Kotlin Multiplatform: the target (× test run) name, e.g. `build/outputs/roborazzi/desktop/`.
- The intermediate directory is separated the same way (e.g. `build/intermediates/roborazzi/debug/`). If you set a custom `outputDir`, the per-slug subdirectory is created under it.
- > [!IMPORTANT]
- > Enabling this option changes where golden images are stored. Existing users must re-record (or manually move) their goldens into the new per-slug subdirectory, otherwise verification will not find them. This is opt-in and defaults to `false`, so existing behavior is unchanged unless you enable it.
- >
- > This also partially addresses requests for per-flavor/variant subdirectories ([#804](https://github.com/takahirom/roborazzi/issues/804), [#731](https://github.com/takahirom/roborazzi/issues/731)).
- <!-- end -->
- <!-- topic_how_to_use -->
- <!-- Generated by docs/topics/how_to_use.md. Do not edit this file. -->
- # How to use
- ## Take a screenshot manually
- You can take a screenshot by calling captureRoboImage().
- app/src/test/java/../ManualTest.kt
- ```kotlin
- import androidx.compose.ui.test.junit4.createAndroidComposeRule
- import androidx.test.core.app.ActivityScenario
- import androidx.test.espresso.Espresso.onView
- import androidx.test.ext.junit.runners.AndroidJUnit4
- import org.junit.Test
- import org.junit.runner.RunWith
- import org.robolectric.annotation.GraphicsMode
- // All you need to do is use the captureRoboImage function in the test!
- import com.github.takahirom.roborazzi.captureRoboImage
- // Tips: You can use Robolectric while using AndroidJUnit4
- @RunWith(AndroidJUnit4::class)
- // Enable Robolectric Native Graphics (RNG)
- @GraphicsMode(GraphicsMode.Mode.NATIVE)
- class ManualTest {
- @get:Rule
- val composeTestRule = createAndroidComposeRule<MainActivity>()
- @Test
- fun captureRoboImageSample() {
- // Tips: You can use Robolectric with Espresso API
- // launch
- ActivityScenario.launch(MainActivity::class.java)
- // Capture screen
- onView(ViewMatchers.isRoot())
- // If you don't specify a screenshot file name, Roborazzi will automatically use the method name as the file name for you.
- // The format of the file name will be as follows:
- // build/outputs/roborazzi/com_..._ManualTest_captureRoboImageSample.png
- .captureRoboImage()
- // Capture Jetpack Compose Node
- composeTestRule.onNodeWithTag("AddBoxButton")
- .onParent()
- .captureRoboImage("build/compose.png")
- }
- }
- ```
- Roborazzi supports the following APIs.
- <table>
- <tr><td>Capture</td><td>Code</td></tr>
- <tr><td>
- ✅ Jetpack Compose's onNode()
- </td><td>
- ```kotlin
- composeTestRule.onNodeWithTag("AddBoxButton")
- .captureRoboImage()
- ```
- </td></tr>
- <tr><td>
- ✅ Espresso's onView()
- </td><td>
- ```kotlin
- onView(ViewMatchers.isRoot())
- .captureRoboImage()
- ```
- ```kotlin
- onView(withId(R.id.button_first))
- .captureRoboImage()
- ```
- </td></tr>
- <tr><td>
- ✅ View
- </td><td>
- ```kotlin
- val view: View = composeTestRule.activity.findViewById<View>(R.id.button_second)
- view.captureRoboImage()
- ```
- </td></tr>
- <tr><td>
- ✅ Jetpack Compose lambda
- </td><td>
- ```kotlin
- captureRoboImage() {
- Text("Hello Compose!")
- }
- ```
- </td></tr>
- <tr><td>
- Experimental🧪<br/>
- ✅ Captures the entire screen, including dialogs
- </td><td>
- ```kotlin
- captureScreenRoboImage()
- ```
- </td></tr>
- <tr><td>
- ✅ Bitmap
- </td><td>
- ```kotlin
- val bitmap: Bitmap = createBitmap(100, 100, Bitmap.Config.ARGB_8888)
- .apply {
- applyCanvas {
- drawColor(android.graphics.Color.YELLOW)
- }
- }
- bitmap.captureRoboImage()
- ```
- </td></tr>
- </table>
- ## Device configuration
- You can configure the device by using the `@Config` annotation and `RobolectricDeviceQualifiers`.
- <table>
- <tr><td>Configuration</td><td>Code</td></tr>
- <tr><td>
- ✅ Predefined device configuration
- </td><td>
- You can change the device configuration by adding `@Config` to the class or method.
- ```kotlin
- @RunWith(AndroidJUnit4::class)
- @GraphicsMode(GraphicsMode.Mode.NATIVE)
- @Config(qualifiers = RobolectricDeviceQualifiers.Pixel5)
- class RoborazziTest {
- ```
- ```kotlin
- @Test
- @Config(qualifiers = RobolectricDeviceQualifiers.Pixel5)
- fun test() {
- ```
- </td></tr>
- <tr><td>
- ✅ Night mode
- </td><td>
- ```kotlin
- @Config(qualifiers = "+night")
- ```
- </td></tr>
- <tr><td>
- ✅ Locale
- </td><td>
- ```kotlin
- @Config(qualifiers = "+ja")
- ```
- </td></tr>
- <tr><td>
- ✅ Screen size
- </td><td>
- ```kotlin
- @Config(qualifiers = RobolectricDeviceQualifiers.MediumTablet)
- ```
- </td></tr>
- </table>
- ## Integrate to your GitHub Actions
- See [Integrate to your GitHub Actions](https://takahirom.github.io/roborazzi/github-actions.html)
- for CI workflows that store, verify, and compare screenshots.
- ## RoborazziRule (Optional)
- RoborazziRule is a JUnit rule for Roborazzi.
- RoborazziRule is **optional**. You can use `captureRoboImage()` without this rule.
- RoborazziRule has two features.
- 1. Provide context such as `RoborazziOptions` and `outputDirectoryPath` etc for `captureRoboImage()`.
- 2. Capture screenshots for each test when specifying RoborazziRule.options.captureType.
- For example, The following code generates an output file
- named `**custom_outputDirectoryPath**/**custom_outputFileProvider**-com.github.takahirom.roborazzi.sample.RuleTestWithPath.captureRoboImage.png` :
- ```kotlin
- @RunWith(AndroidJUnit4::class)
- @GraphicsMode(GraphicsMode.Mode.NATIVE)
- class RuleTestWithPath {
- @get:Rule
- val roborazziRule = RoborazziRule(
- options = Options(
- outputDirectoryPath = "$DEFAULT_ROBORAZZI_OUTPUT_DIR_PATH/custom_outputDirectoryPath",
- outputFileProvider = { description, outputDirectory, fileExtension ->
- File(
- outputDirectory,
- "custom_outputFileProvider-${description.testClass.name}.${description.methodName}.$fileExtension"
- )
- }
- ),
- )
- @Test
- fun captureRoboImage() {
- launch(MainActivity::class.java)
- // The file will be saved using the rule's outputDirectoryPath and outputFileProvider
- onView(isRoot()).captureRoboImage()
- }
- }
- ```
- To record test interactions as animated images (`captureRoboGif()`, `recordRoboVideo()`),
- see [Capture GIFs and videos](https://takahirom.github.io/roborazzi/gif-and-video.html).
- ### RoborazziRule options
- `RoborazziRule.Options` has:
- - `captureType` — what the rule captures per test: `None` (default; the rule only provides
- context), `LastImage`, `AllImage` (an image per layout change, like `TestClass_method_0.png`),
- or `Gif`. The image-generating types take `onlyFail = true` to capture only when the test
- fails. Annotate a test with `@RoborazziRule.Ignore` to exclude it from these capture types.
- - `outputDirectoryPath` / `outputFileProvider` — where output files go and how they are named.
- - `roborazziOptions` — the `RoborazziOptions` provided to `captureRoboImage()` in the test.
- See [RoborazziRule](https://github.com/takahirom/roborazzi/blob/main/roborazzi-junit-rule/src/main/java/com/github/takahirom/roborazzi/RoborazziRule.kt)
- for the full definition.
- #### Image comparator custom settings
- When comparing images, you may encounter differences due to minor changes related to antialiasing. You can use the options below to avoid this.
- ```kotlin
- @get:Rule
- val roborazziRule = RoborazziRule(
- options = RoborazziRule.Options(
- roborazziOptions = RoborazziOptions(
- compareOptions = RoborazziOptions.CompareOptions(
- changeThreshold = 0.01, // For 1% accepted difference
- imageComparator = SimpleImageComparator(
- maxDistance = 0.007F, // 0.001F is default value from Differ
- vShift = 2, // Increasing the shift can help resolve antialiasing issues
- hShift = 2 // Increasing the shift can help resolve antialiasing issues
- )
- )
- )
- )
- )
- ```
- ## Experimental WebP support and other image formats
- You can set `roborazzi.record.image.extension` to `webp` in your `gradle.properties` file to generate WebP images.
- ```kotlin
- roborazzi.record.image.extension=webp
- ```
- WebP is a lossy image format by default, which can make managing image differences challenging. To address this, we provide a lossless WebP image comparison feature.
- To enable WebP support, add `testImplementation("io.github.darkxanter:webp-imageio:0.3.3")` to your `build.gradle.kts` file.
- ```kotlin
- onView(ViewMatchers.withId(R.id.textview_first))
- .captureRoboImage(
- roborazziOptions = RoborazziOptions(
- recordOptions = RoborazziOptions.RecordOptions(
- imageIoFormat = LosslessWebPImageIoFormat(),
- ),
- )
- )
- ```
- You can also use other image formats by implementing your own `AwtImageWriter` and `AwtImageLoader`.
- ```kotlin
- data class JvmImageIoFormat(
- val awtImageWriter: AwtImageWriter,
- val awtImageLoader: AwtImageLoader
- ) : ImageIoFormat
- ```
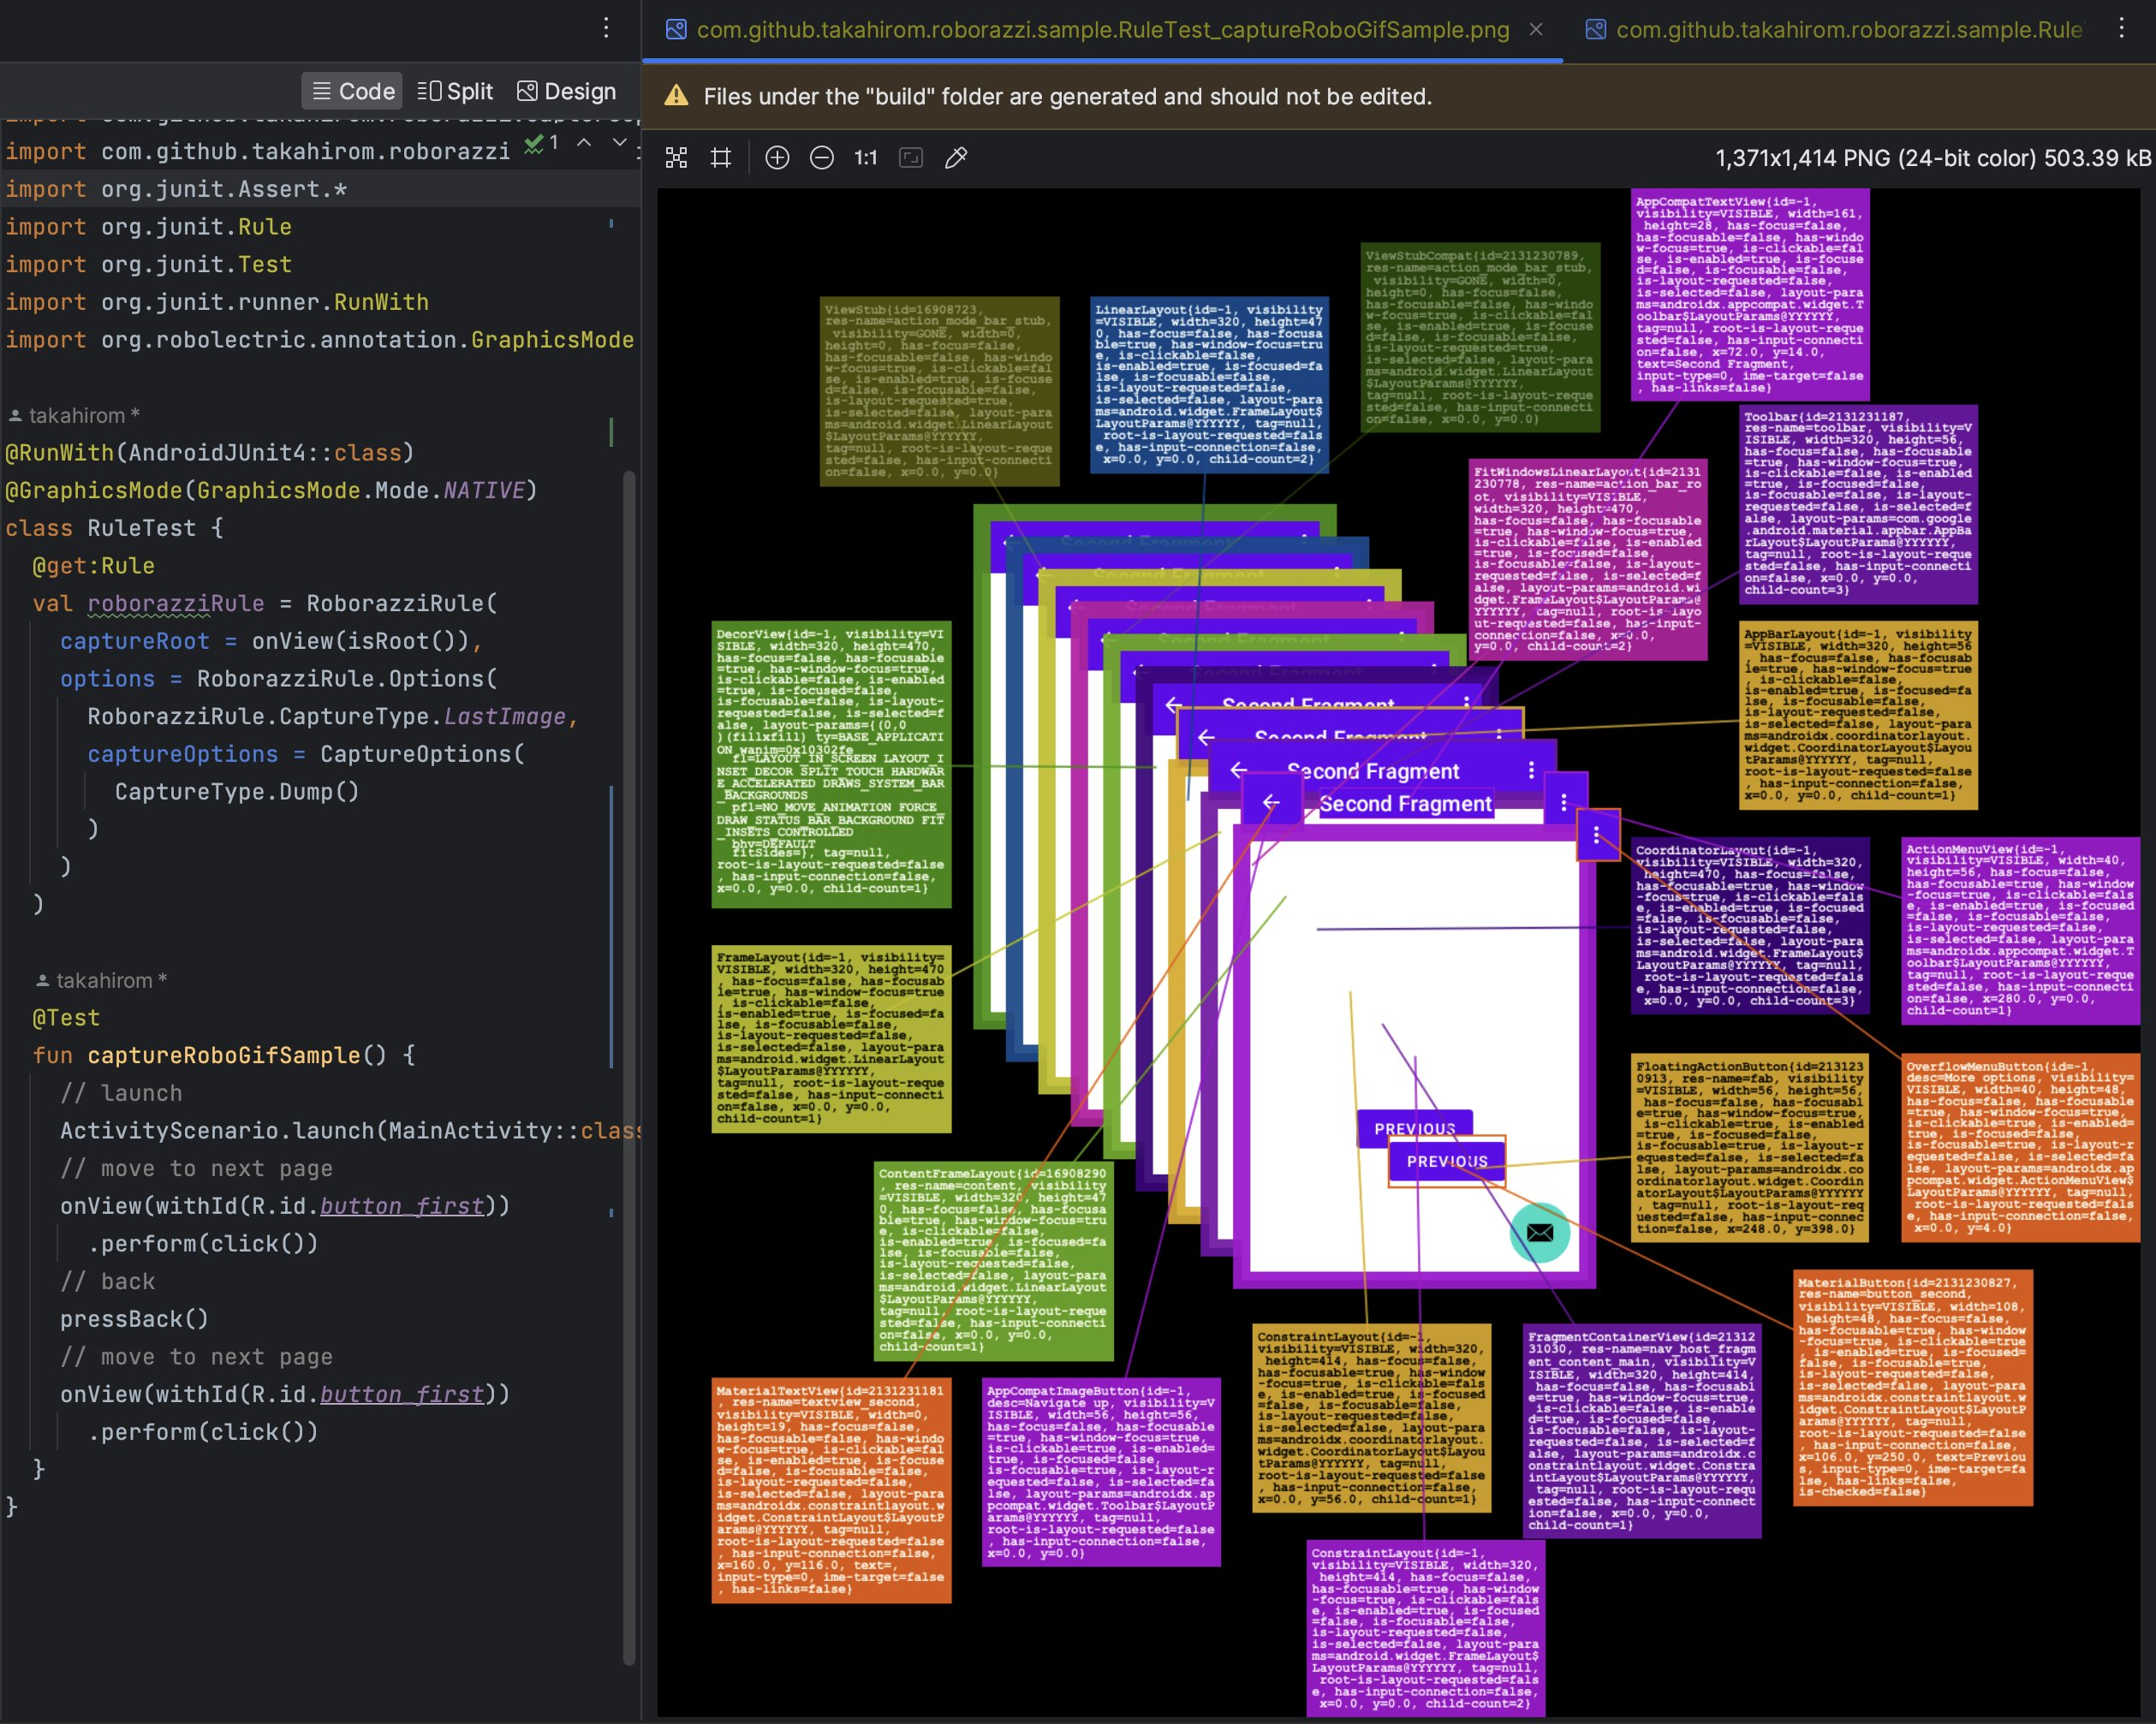
- ## Dump mode
- If you are having trouble debugging your test, try Dump mode as follows.
- 
- For a machine-readable version of the UI tree for tools and AI agents, see
- [UI tree dump (JSON)](https://takahirom.github.io/roborazzi/ui-tree-dump.html).
- ## Accessibility Check
- Roborazzi Accessibility Checks is a library that integrates accessibility checks into Roborazzi.
- Please refer to [Accessibility Check](https://github.com/takahirom/roborazzi/blob/main/roborazzi-accessibility-check/README.md)
- ## Accessibility legend
- The `AccessibilityLegend` capture type (experimental) renders the screenshot next to a legend of the elements a screen
- reader focuses, numbered in traversal order. It is recorded and verified like any other screenshot, so a changed label,
- role, state or order shows up as a golden diff.
- ```kotlin
- composeTestRule.onRoot().captureRoboImage(
- roborazziOptions = RoborazziOptions(
- captureType = RoborazziOptions.CaptureType.AccessibilityLegend(),
- ),
- )
- ```
- <img src="https://github.com/user-attachments/assets/0a05ee3d-befb-46ca-8554-187df0dacd53" alt="Accessibility legend example" width="600" />
- For each element the legend shows:
- - the label: content description or text; for a clickable container, the texts of its descendants;
- - the role (Button, Checkbox, Switch, Tab, Slider, Heading, EditText, …), the state (checked, selected, disabled or a
- state description) and the value of sliders and progress bars;
- - for text fields, the value, hint, error and whether it is a password;
- - live regions and pane titles;
- - `⚠ NO LABEL` for a clickable element without a label.
- The numbers sit in a column next to the screenshot, so they don't cover the UI. Colors come from a hash of the element's
- text, so inserting an element rarely recolors the others.
- Compose content is read from the merged semantics tree in the order Compose reports to screen readers. Views are read
- from `AccessibilityNodeInfo`, so `AccessibilityDelegate`s are taken into account. Compose computes the order only while
- a screen reader is on, so the capture turns one on in Robolectric while it reads the tree and restores the previous
- state afterwards. The screenshot itself is taken before that.
- The legend approximates what TalkBack reads; it doesn't run TalkBack. It works on Android with Robolectric only.
- Views that expose virtual children through their own `AccessibilityNodeProvider` (for example charts or custom widgets)
- are not expanded: their virtual children don't appear in the legend.
- ## Roborazzi options
- Please check out [RoborazziOptions](https://github.com/takahirom/roborazzi/blob/main/include-build/roborazzi-core/src/commonJvmMain/kotlin/com/github/takahirom/roborazzi/RoborazziOptions.kt) for available Roborazzi options.
- <!-- end -->
- <!-- topic_ui_tree_dump -->
- <!-- Generated by docs/topics/ui_tree_dump.md. Do not edit this file. -->
- # UI tree dump (JSON)
- While [Dump mode](https://takahirom.github.io/roborazzi/how-to-use.html#dump-mode)
- renders the UI tree *into an image* for humans, **UI tree dump** writes a
- machine-readable JSON **sidecar** next to the screenshot it describes, for tools
- and AI agents to read. When enabled, capturing `MyTest.png` also writes
- `MyTest.uitree.json` (the Compose semantics + View hierarchy of the current run)
- and, by default, an annotated `MyTest.annotated.png` (see
- [Annotated image](#annotated-image-set-of-mark) below).
- The sidecar is written on record and compare/verify, next to the image the task
- writes: `MyTest.uitree.json` on record, and `MyTest_actual.uitree.json` in the
- compare output directory on compare/verify (an unchanged verify still writes it).
- The sidecar is **informational only**: it never participates in image diffing and
- never fails verification. Bitmap-based `captureRoboImage(Bitmap...)` captures
- (which have no component tree) do not produce one.
- Supported on Android/Robolectric, Compose Desktop, and Compose iOS, with identical
- output.
- ## Enabling it
- Via the Gradle property (no code change):
- ```shell
- ./gradlew recordRoborazziDebug -Proborazzi.dumpUiTree=true
- ```
- Or per capture via `RoborazziOptions`:
- ```kotlin
- onView(ViewMatchers.isRoot())
- .captureRoboImage(
- roborazziOptions = RoborazziOptions(
- uiTreeDumpOptions = UiTreeDumpOptions()
- )
- )
- ```
- ## Format
- ```json
- { "schemaVersion": 1, "capture": { "imageWidth": 220, "imageHeight": 100, "scale": 1.0 }, "root":
- { "type": "view", "className": "androidx.compose.ui.platform.ComposeView", "bounds": [0, 0, 220, 100], "children": [
- { "n": 1, "type": "compose", "testTag": "login_button", "bounds": [16, 24, 204, 72], "properties": { "Role": "Button", "Text": "Login" }, "actions": ["OnClick"], "flags": ["MergeDescendants"] },
- { "n": 2, "type": "compose", "bounds": [16, 80, 204, 96], "properties": { "Text": "Forgot password?" } } ] }
- }
- ```
- The format is deliberately grep-first: one node per line with all of its scalar
- attributes, so a single `grep` finds a node and its coordinates.
- * `bounds` is `[left, top, right, bottom]` in **RAW (unscaled) window pixel**
- coordinates; the root `capture` object carries the output `imageWidth`/
- `imageHeight` and `scale`. Map to image pixels with
- `image = (raw − root.bounds origin) × capture.scale` — the root origin is
- `0, 0` for full-screen captures.
- * Empty/default fields are omitted (no empty maps/lists, no `visibility` when the
- node is visible).
- * `n` is a sequential (1-based, pre-order) number on *annotatable* nodes only —
- visible nodes with a test tag, a `Text`/`ContentDescription`, or an action; a
- numbered `MergeDescendants` node's descendants are skipped.
- * Output is **deterministic**: the same UI produces byte-identical JSON (no
- timestamps, no hashes).
- ## Annotated image (Set-of-Mark)
- "Set-of-Mark" refers to a prompting technique for vision-language models:
- overlaying numbered marks on image regions lets a model refer to a region
- unambiguously by its number ([Yang et al., 2023](https://arxiv.org/abs/2310.11441)).
- <img width="440" alt="Annotated Set-of-Mark image" src="https://github.com/user-attachments/assets/208593c3-cd2b-4c0a-ae5b-e7cf6cd0260e" />
- Written by default next to the screenshot — a copy of the output with every
- numbered node drawn as a labelled box — under the same naming as the sidecar:
- `MyTest.annotated.png` on record, `MyTest_actual.annotated.png` on compare/verify
- (an unchanged verify annotates the identical golden).
- Each box's number is the same `n` as in the JSON, so an agent can point at
- "element #3" and look up `"n": 3` for its exact bounds, properties, and actions.
- The annotated image is a **display artifact of the current run only** — never
- compared, never failing a capture, never treated as a golden. Opt out with
- `UiTreeDumpOptions(annotateImage = false)`.
- The annotated image is only written for the default screenshot capture type. Other
- capture types, such as `CaptureType.Dump()`, place the screenshot among other
- content, so the boxes would be drawn in the wrong place; for them only the sidecar
- is written.
- ## Primary use case: letting an AI agent prove its UI fixes
- AI agents are bad at judging small layout changes from screenshots — ask one to
- "add margin above the button" and it will often claim "fixed" when nothing moved.
- The deterministic UI tree gives it exact coordinates to check instead, so the
- agent can read the button's bounds before and after and prove the change actually
- landed.
- 1. Record and read the node line:
- ```shell
- ./gradlew recordRoborazziDebug -Proborazzi.dumpUiTree=true
- grep login_button build/outputs/roborazzi/MyTest.uitree.json
- # { "n": 1, "testTag": "login_button", "bounds": [16, 24, 204, 72], ... }
- ```
- `bounds` is `[left, top, right, bottom]`, so the top edge is at `24`.
- 2. Make the change, keeping that `before` value in context.
- 3. Re-record (it overwrites the sidecar in place) and grep the same line:
- ```text
- # { "n": 1, "testTag": "login_button", "bounds": [16, 32, 204, 80], ... }
- ```
- Top moved `24 → 32` — the button provably sits 8px lower. (To prove a *gap*,
- also compare the sibling above: its `bottom` vs this `top`.) Because the output
- is deterministic, any change in the numbers is a real layout change, not noise.
- <!-- end -->
- <!-- topic_github_actions -->
- <!-- Generated by docs/topics/github_actions.md. Do not edit this file. -->
- # Integrate to your GitHub Actions
- It is easy to integrate Roborazzi to your GitHub Actions.
- ## Add a job to store screenshots
- ```yaml
- name: store screenshots
- on:
- push
- env:
- GRADLE_OPTS: "-Dorg.gradle.jvmargs=-Xmx6g -Dorg.gradle.daemon=false -Dkotlin.incremental=false"
- jobs:
- test:
- runs-on: macos-latest
- steps:
- - uses: actions/checkout@v4
- - uses: actions/setup-java@v4
- with:
- distribution: 'zulu'
- java-version: 19
- - name: Setup Gradle
- uses: gradle/actions/setup-gradle@v4
- - name: test
- run: |
- # Create screenshots
- ./gradlew app:recordRoborazziDebug --stacktrace
- # Upload screenshots to GitHub Actions Artifacts
- - uses: actions/upload-artifact@v4
- with:
- name: screenshots
- path: app/build/outputs/roborazzi
- retention-days: 30
- ```
- ## Add a job to verify screenshots
- ```yaml
- name: verify test
- on:
- push
- env:
- GRADLE_OPTS: "-Dorg.gradle.jvmargs=-Xmx6g -Dorg.gradle.daemon=false -Dkotlin.incremental=false"
- jobs:
- test:
- runs-on: macos-latest
- steps:
- - uses: actions/checkout@v4
- - uses: actions/setup-java@v4
- with:
- distribution: 'zulu'
- java-version: 19
- - name: Setup Gradle
- uses: gradle/actions/setup-gradle@v4
- # Download screenshots from main branch
- - uses: dawidd6/action-download-artifact@v6
- with:
- name: screenshots
- path: app/build/outputs/roborazzi
- workflow: test.yaml
- branch: main
- - name: verify test
- id: verify-test
- run: |
- # If there is a difference between the screenshots, the test will fail.
- ./gradlew app:verifyRoborazziDebug --stacktrace
- - uses: actions/upload-artifact@v4
- if: ${{ always() }}
- with:
- name: screenshot-diff
- path: app/build/outputs/roborazzi
- retention-days: 30
- - uses: actions/upload-artifact@v4
- if: ${{ always() }}
- with:
- name: screenshot-diff-reports
- path: app/build/reports
- retention-days: 30
- - uses: actions/upload-artifact@v4
- if: ${{ always() }}
- with:
- name: screenshot-diff-test-results
- path: app/build/test-results
- retention-days: 30
- ```
- ## Advanced workflow Sample: Compare Snapshot Results on Pull Requests
- For those who are looking for a more advanced example, we have prepared a sample repository that
- demonstrates how to use Roborazzi to compare snapshot results on GitHub pull requests. This sample
- showcases the integration of Roborazzi with GitHub Actions workflows, making it easy to visualize
- and review the differences between snapshots directly in the pull request comments.
- Check out
- the [roborazzi-compare-on-github-comment-sample](https://github.com/takahirom/roborazzi-compare-on-github-comment-sample)
- repository to see this powerful feature in action and learn how to implement it in your own
- projects.
- Example of the comment
- <img alt="Example of a Roborazzi screenshot comparison comment on a GitHub pull request" src="https://user-images.githubusercontent.com/1386930/236480693-80483cde-53fe-4c04-ba1f-2352e14b5f15.png" width="600" />
- <!-- end -->
- <!-- topic_gif_and_video -->
- <!-- Generated by docs/topics/gif_and_video.md. Do not edit this file. -->
- # Capture GIFs and videos
- Roborazzi can record test interactions as animated images: `captureRoboGif()`
- captures visually distinct states as a GIF, and `recordRoboVideo()` records
- animations frame by frame over virtual time.
- ## Generate gif image
- ```kotlin
- @Test
- fun captureRoboGifSample() {
- onView(ViewMatchers.isRoot())
- .captureRoboGif("build/test.gif") {
- // launch
- ActivityScenario.launch(MainActivity::class.java)
- // move to next page
- onView(withId(R.id.button_first))
- .perform(click())
- // back
- pressBack()
- // move to next page
- onView(withId(R.id.button_first))
- .perform(click())
- }
- }
- ```
- <img alt="GIF of the test interactions captured by captureRoboGif" width="350" src="https://user-images.githubusercontent.com/1386930/226362212-35d34c9e-6df1-4671-8949-10fad7ad98c9.gif" />
- ## Generate gif with test rule
- > **Note**
- > You **don't need to use RoborazziRule** if you're using captureRoboGif().
- With the JUnit test rule, you do not need to name the gif image,
- and if you prefer, you can output the gif image **only if the test fails**.
- This test will output this file.
- `build/outputs/roborazzi/com.github.takahirom.roborazzi.sample.RuleTestWithOnlyFail_captureRoboGifSampleFail.gif`
- ```kotlin
- @RunWith(AndroidJUnit4::class)
- @GraphicsMode(GraphicsMode.Mode.NATIVE)
- class RuleTestWithOnlyFail {
- @get:Rule
- val roborazziRule = RoborazziRule(
- captureRoot = onView(isRoot()),
- options = Options(
- captureType = RoborazziRule.CaptureType.Gif(
- onlyFail = true
- ),
- )
- )
- @Test
- fun captureRoboGifSampleFail() {
- // launch
- ActivityScenario.launch(MainActivity::class.java)
- // move to next page
- onView(withId(R.id.button_first))
- .perform(click())
- // should fail because the button does not exist
- // Due to failure, the gif image will be saved in the outputs folder.
- onView(withId(R.id.button_first))
- .perform(click())
- }
- }
- ```
- ## Generate Jetpack Compose gif with test rule
- Test target
- ```kotlin
- @Composable
- fun SampleComposableFunction() {
- var count by remember { mutableStateOf(0) }
- Column(
- Modifier
- .size(300.dp)
- ) {
- Box(
- Modifier
- .testTag("AddBoxButton")
- .size(50.dp)
- .clickable {
- count++
- }
- )
- (0..count).forEach {
- Box(
- Modifier
- .size(30.dp)
- )
- }
- }
- }
- ```
- Test (Just add RoborazziRule)
- ```kotlin
- @RunWith(AndroidJUnit4::class)
- @GraphicsMode(GraphicsMode.Mode.NATIVE)
- class ComposeTest {
- @get:Rule
- val composeTestRule = createAndroidComposeRule<ComponentActivity>()
- @get:Rule
- val roborazziRule = RoborazziRule(
- composeRule = composeTestRule,
- captureRoot = composeTestRule.onRoot(),
- options = RoborazziRule.Options(
- RoborazziRule.CaptureType.Gif()
- )
- )
- @Test
- fun composable() {
- composeTestRule.setContent {
- SampleComposableFunction()
- }
- (0 until 3).forEach { _ ->
- composeTestRule
- .onNodeWithTag("AddBoxButton")
- .performClick()
- }
- }
- }
- ```
- 
- ## Record a video of the UI (experimental)
- `recordRoboVideo()` records how the UI evolves over virtual time -- animations, transitions,
- gestures and any other time-driven change -- as an animated image that plays back in real time.
- Unlike `captureRoboGif()`, which only records visually distinct states with a fixed 1-second
- delay, it pauses the Compose main clock and drives it frame by frame, so intermediate animation
- frames are captured with faithful timing. Interactions in the block run with the clock paused;
- call `delay()` in the scope to advance virtual time while frames are recorded. After the block
- returns, recording continues until the UI settles, so a block that only performs a click still
- records the whole animation the click starts.
- ```kotlin
- @OptIn(ExperimentalRoborazziApi::class)
- @Test
- fun recordVideo() {
- composeTestRule.setContent {
- AnimatedBoxContent()
- }
- composeTestRule.onNodeWithTag("root")
- .recordRoboVideo(
- composeRule = composeTestRule,
- filePath = "build/outputs/roborazzi/video.gif",
- videoOptions = RoboVideoOptions(fps = 10),
- ) {
- composeTestRule.onNodeWithTag("toggle").performClick()
- delay(300)
- composeTestRule.onNodeWithTag("toggle").performClick()
- delay(300)
- }
- }
- ```
- - `RoboVideoOptions`: `fps` (default `10`), `settleTimeoutMillis` (additional virtual time to
- keep recording while the UI is still changing after the block ends; default `3000`), and
- `backgroundColor` (ARGB fill for the fixed recording viewport when frames have different
- sizes; default white).
- - **Output format is chosen by the file extension:** `.gif` produces a GIF (256 colors; the
- default), `.png` a lossless, full-color APNG (Animated PNG) -- prefer `.png` when color
- fidelity matters. Only these animated-image formats are supported for now; the "video" name
- was chosen deliberately so real video formats (e.g. mp4) can be added later without renaming
- the API.
- - GIF stores frame delays in centiseconds (10ms resolution), so prefer an `fps` whose frame step
- (`1000 / fps`) is a multiple of 10ms (e.g. 10, 20, 25, 50) for exact GIF timing. APNG encodes
- the step exactly.
- - The API is experimental (`@ExperimentalRoborazziApi`) and currently only supports recording:
- when the Roborazzi task runs in compare/verify mode it is a complete no-op -- the block is not
- executed and no image is recorded or verified.
- `recordScreenRoboVideo()` records all window roots instead of a single node, mirroring how
- `captureScreenRoboImage()` relates to `captureRoboImage()`. Prefer it when you want a stable,
- device-sized viewport for every frame, or to capture window overlays such as dialogs added
- mid-recording or touch/tap indicators, which live on separate window roots and are invisible to a
- node-scoped recording. Usage is the same, just without node scoping:
- ```kotlin
- recordScreenRoboVideo(
- composeRule = composeTestRule,
- filePath = "build/outputs/roborazzi/video_screen.gif",
- videoOptions = RoboVideoOptions(fps = 10),
- ) {
- composeTestRule.onNodeWithTag("toggle").performClick()
- delay(300)
- }
- ```
- Because the recorder idles the Robolectric main Looper in lockstep with the Compose main clock,
- suspend-based gesture drivers make progress while frames are recorded. For example, you can drive
- a swipe with [saket/touch-robot](https://github.com/saket/touch-robot) from a `LaunchedEffect`,
- use `recordScreenRoboVideo()` so the touch indicator overlay is captured, and just pump virtual
- time in the block:
- ```kotlin
- composeTestRule.setContent {
- // A composable whose LaunchedEffect drives a touch-robot swipe on the root.
- DraggableBoxContent()
- }
- recordScreenRoboVideo(
- composeRule = composeTestRule,
- filePath = "build/outputs/roborazzi/swipe.gif",
- ) {
- // Pump virtual time so the LaunchedEffect gesture progresses while frames are captured.
- delay(1000)
- }
- ```
- <!-- end -->
- <!-- topic_preview_support -->
- <!-- Generated by docs/topics/preview_support.md. Do not edit this file. -->
- # Experimental Compose Preview Support
- Roborazzi provides support for generating screenshot tests and easy setup for Jetpack Compose Preview.
- This support uses [ComposablePreviewScanner](https://github.com/sergio-sastre/ComposablePreviewScanner) to scan the Composable Previews in your project.
- ## Generate Compose Preview screenshot tests
- You first need to add the Roborazzi plugin to your project. Please refer to the [setup guide](https://takahirom.github.io/roborazzi/build-setup.html) for more information.
- Then you can enable the Compose Preview screenshot test generation feature by adding the following configuration to your `build.gradle.kts` file:
- ```kotlin
- roborazzi {
- generateComposePreviewRobolectricTests {
- enable = true
- }
- }
- ```
- The plugin will not automatically change your settings or add dependencies to prevent conflicts with your existing setup. However, it will provide instructions on what to do next, such as adding dependencies and required code. You can also check the [sample project](https://github.com/takahirom/roborazzi/tree/main/sample-generate-preview-tests) for a complete example.
- After that, you can run the `recordRoborazziDebug` task to generate screenshots using the generated tests, as described in the [setup guide](https://takahirom.github.io/roborazzi/build-setup.html).
- ### Customizing the Preview screenshot test
- You can customize the generated test by adding the following configuration to your `build.gradle.kts` file:
- ```kotlin
- roborazzi {
- @OptIn(ExperimentalRoborazziApi::class)
- generateComposePreviewRobolectricTests {
- enable = true
- // The package names to scan for Composable Previews.
- packages = listOf("com.example")
- // robolectricConfig will be passed to Robolectric's @Config annotation in the generated test class.
- // See https://robolectric.org/configuring/ for more information.
- robolectricConfig = mapOf(
- "sdk" to "[32]",
- "qualifiers" to "RobolectricDeviceQualifiers.Pixel5",
- )
- // If true, the private previews will be included in the test.
- includePrivatePreviews = true
- // The fully qualified class name of the custom test class that implements [com.github.takahirom.roborazzi.ComposePreviewTester].
- testerQualifiedClassName = "com.example.MyCustomComposePreviewTester"
- // The number of test classes to generate. Set this to match maxParallelForks for parallel test execution.
- generatedTestClassCount = 4
- // Experimental: render at a lower density to make the tests faster and the images smaller.
- // See "Making the tests faster with renderScale" below.
- // renderScale = 1.0 / 3
- // Filter previews by annotation. See "Filtering previews by annotation" below.
- annotationFilter = AnnotationFilter.Filter.RoboPreviewInclude
- }
- }
- ```
- #### Advanced: Custom ComposePreviewTester Implementation
- You can create a custom `ComposePreviewTester` to control the screenshot capture behavior, such as setting a custom image comparison threshold.
- Note that `AndroidComposePreviewTester` is a final class, so you can't subclass it. Instead, use Kotlin class delegation and pass a custom `Capturer` to its constructor. Also, your tester class must have a parameterless constructor because the plugin instantiates it via reflection:
- ```kotlin
- import com.dropbox.differ.SimpleImageComparator
- import com.github.takahirom.roborazzi.*
- import com.github.takahirom.roborazzi.ComposePreviewTester.TestParameter.JUnit4TestParameter.AndroidPreviewJUnit4TestParameter
- @OptIn(ExperimentalRoborazziApi::class)
- class MyCustomComposePreviewTester :
- ComposePreviewTester<AndroidPreviewJUnit4TestParameter> by AndroidComposePreviewTester(
- capturer = { parameter ->
- val customOptions = parameter.roborazziOptions.copy(
- compareOptions = parameter.roborazziOptions.compareOptions.copy(
- // Set custom comparison threshold (0.0 = exact match, 1.0 = ignore differences)
- imageComparator = SimpleImageComparator(maxDistance = 0.01f)
- )
- )
- AndroidComposePreviewTester.DefaultCapturer().capture(
- parameter.copy(roborazziOptions = customOptions)
- )
- }
- )
- ```
- If you need to customize more than the capture behavior, such as the scan options or the test lifecycle, you can override `options()` or `test()` in the delegating class.
- `Options` is how the Gradle extension reaches your tester: the generated test assigns the configured values to `ComposePreviewTester.defaultOptionsFromPlugin`, and the default `options()` returns them. So when you override `options()`, derive the result with `super.options().copy(...)` instead of constructing a new `Options`, otherwise every setting the plugin configured is silently replaced by defaults. The same applies if you implement `test()` or the capture yourself: read the values from `options()` rather than assuming defaults.
- Two settings need extra care with a custom tester:
- - `includePrivatePreviews` and `annotationFilter` are consumed by `testParameters()`. Because a custom tester usually overrides it, the plugin rejects the combination unless you set `useScanOptionParametersInTester = true` and read `options().scanOptions` yourself.
- - `renderScale` (see [Making the tests faster with `renderScale`](#making-the-tests-faster-with-renderscale)) is consumed at capture time, so the class-delegation pattern above keeps working. If you override `test()` yourself, see the `renderScale` property documentation for what to pass to `preview.toRoborazziComposeOptions(renderScale)`. A tester that drops the value fails the generated test with an explanation, so a silently unscaled screenshot is not possible.
- Then reference your custom tester in the Gradle configuration:
- ```kotlin
- roborazzi {
- @OptIn(ExperimentalRoborazziApi::class)
- generateComposePreviewRobolectricTests {
- enable = true
- testerQualifiedClassName = "com.example.MyCustomComposePreviewTester"
- }
- }
- ```
- > [!NOTE]
- > If you are using Groovy DSL instead of Kotlin DSL, you need to use the set method for each assignment:
- > ```kotlin
- > generateComposePreviewRobolectricTests.enable.set(true)
- > generateComposePreviewRobolectricTests.packages.set(["com.example"])
- > ```
- ### Making the tests faster with `renderScale`
- If the generated tests are slow or the recorded images are large, `renderScale` is the knob for it.
- A value below 1.0 renders every preview at a lower device density, so fewer pixels are rendered:
- the tests spend less time rendering and the images take less space. What you pay for it is
- fidelity, so it pays off on previews that stay readable at the smaller size.
- What the scale does and does not change — density-qualified resources, raw-pixel drawing, the dpi
- rounding, when it is applied — is documented on the `renderScale` property itself, which your IDE
- shows as you type it.
- `renderScale` is not the same as `resizeScale`:
- | Property | When it applies | What it changes |
- | --- | --- | --- |
- | `renderScale` | Before Compose renders | Device density. Logical dp dimensions are preserved, so a smaller surface is rendered. Density-qualified resources (`drawable-hdpi` and so on) may resolve differently. |
- | `resizeScale` (`RoborazziOptions.RecordOptions`, `roborazzi.record.resizeScale`) | After the screenshot is captured | Downsamples the captured bitmap. Rendering cost is unchanged. |
- Both change the recorded image dimensions at the same output paths, so existing golden images have to be recorded again after you set either of them.
- In the Groovy DSL, write the value as a `double` literal: `renderScale = 0.5d`. A bare `0.5` is a `BigDecimal` and fails to convert.
- To scale a single preview differently, annotate it with `@RoboComposePreviewOptions(renderScale = ...)`. This is useful when only a few previews are large enough to be worth the loss of fidelity:
- ```kotlin
- @RoboComposePreviewOptions(renderScale = 0.5)
- @Preview(device = "spec:width=1280dp,height=800dp,dpi=240")
- @Composable
- fun TabletPreview() {
- }
- ```
- Previews without the annotation keep the scale configured in the Gradle extension.
- ### Filtering previews by annotation
- `annotationFilter` controls which previews are captured (requires the `roborazzi-annotations` dependency).
- By default it is `AnnotationFilter.Filter.RoboPreviewExclude`, so previews annotated with
- `@RoboPreviewExclude` are skipped. Set it to `RoboPreviewInclude` to capture **only** previews
- annotated with `@RoboPreviewInclude`:
- ```kotlin
- roborazzi {
- @OptIn(ExperimentalRoborazziApi::class)
- generateComposePreviewRobolectricTests {
- enable = true
- packages = listOf("com.example")
- annotationFilter = AnnotationFilter.Filter.RoboPreviewInclude
- }
- }
- ```
- To filter by your own annotations, pass their fully qualified class names
- (use the JVM binary name with `$` for nested classes, e.g. `com.example.Outer$Inner`):
- ```kotlin
- // Set either one, not both
- annotationFilter = AnnotationFilter.Exclude("com.example.MyExcludeAnnotation")
- annotationFilter = AnnotationFilter.Include("com.example.MyIncludeAnnotation")
- ```
- ### Compose Multiplatform previews
- The Compose Preview support also works with Compose Multiplatform common previews (`@Preview` in `commonMain`). You can scan them with the `CommonComposablePreviewScanner` from the ComposablePreviewScanner `common` artifact in a custom tester; the generated tests run as Android unit tests with Robolectric. See the [multiplatform sample project](https://github.com/takahirom/roborazzi/tree/main/sample-generate-preview-tests-multiplatform) for a complete setup.
- ## Experimental Compose Desktop Preview Support
- Roborazzi can also generate preview screenshot tests for the Compose Desktop (JVM)
- target, without Robolectric. Previews are scanned with ComposablePreviewScanner's
- `android` artifact, which is a pure-JVM jar: it finds the multiplatform
- `androidx.compose.ui.tooling.preview.Preview` annotation on the classpath, so previews
- declared in `commonMain` are captured too.
- ### Robolectric or Desktop — trade-offs
- - **Fidelity**: Robolectric renders with the Android framework; desktop renders with the
- host's Skia, so the same preview produces different images — goldens are per-platform.
- - **Speed**: desktop tests run roughly 4–6x faster than the Robolectric ones ([benchmark](https://github.com/takahirom/roborazzi/pull/903)).
- - **Adoption cost**: requires a Kotlin JVM target — a Kotlin Multiplatform `jvm()`
- target or a plain `org.jetbrains.kotlin.jvm` project. For an Android-only project
- that means a KMP migration first — stick with the Robolectric preview tests there.
- Desktop tests shine for already-multiplatform code and Desktop-only apps.
- Enable it in your `build.gradle.kts`:
- ```kotlin
- roborazzi {
- @OptIn(ExperimentalRoborazziApi::class)
- generateComposePreviewDesktopTests {
- enable = true
- packages = listOf("com.example")
- // Required only when the project has multiple Kotlin JVM targets:
- // targetName = "desktop"
- }
- }
- ```
- Add the dependencies to the JVM target's test source set. If your previews use the
- Roborazzi marker annotations (`@RoboPreviewExclude`, `@RoboComposePreviewOptions`, ...),
- also add `roborazzi-annotations` to the source set that declares the previews
- (usually `commonMain` — test dependencies do not flow into main source sets):
- ```kotlin
- kotlin {
- sourceSets {
- val commonMain by getting {
- dependencies {
- // Only needed when previews use the Roborazzi marker annotations
- implementation("io.github.takahirom.roborazzi:roborazzi-annotations:[version]")
- }
- }
- val desktopTest by getting {
- dependencies {
- implementation("io.github.takahirom.roborazzi:roborazzi-compose-desktop-preview-scanner-support:[version]")
- implementation("io.github.sergio-sastre.ComposablePreviewScanner:android:[version]")
- implementation("junit:junit:4.13.2")
- }
- }
- }
- }
- ```
- Plain JVM projects (`org.jetbrains.kotlin.jvm`) are also supported: add the same
- dependencies with `testImplementation(...)` and use the `Jvm` task names
- (`recordRoborazziJvm`, `compareRoborazziJvm`, `verifyRoborazziJvm`).
- Then run the desktop Roborazzi tasks:
- ```shell
- ./gradlew recordRoborazziDesktop
- ./gradlew compareRoborazziDesktop
- ./gradlew verifyRoborazziDesktop
- ```
- Note: ComposablePreviewScanner is published with JVM 17 metadata, so the desktop
- target needs to target JVM 17 (or relax the test classpath's `TargetJvmVersion`
- attribute). See the [desktop multiplatform sample](https://github.com/takahirom/roborazzi/tree/main/sample-compose-desktop-multiplatform)
- for a complete setup, including manual usage of the tester API without the generator.
- ### Screenshot naming and mixed modules
- Desktop preview screenshots use the same file names as the Robolectric preview tests
- (fully qualified class name + method name + preview parameter suffix), so the same
- preview produces the same file name on both platforms. If one module enables **both**
- `generateComposePreviewRobolectricTests` and `generateComposePreviewDesktopTests`, the
- two sets of screenshots would overwrite each other in the shared output directory, so
- Roborazzi fails with a configuration error unless
- [`separateOutputDirs`](https://takahirom.github.io/roborazzi/build-setup.html#separate-output-directories-per-varianttarget-experimental)
- is enabled, which gives each task its own subdirectory.
- ### Customizing the desktop tester
- `DefaultDesktopComposePreviewTester` accepts a `Capturer` whose receiver is the raw
- `ComposeUiTest` scope, so anything possible inside `runDesktopComposeUiTest` — clock
- control, interactions, wrapping the content in a theme — stays possible:
- ```kotlin
- @OptIn(ExperimentalRoborazziApi::class, ExperimentalTestApi::class)
- class MyDesktopPreviewTester : DesktopComposePreviewTester by DefaultDesktopComposePreviewTester(
- capturer = DefaultDesktopComposePreviewTester.Capturer { parameter ->
- setContent { MyTheme { parameter.preview() } }
- // Keep @RoboComposePreviewOptions manualClockOptions working: without this,
- // time-suffixed captures would all show the initial state.
- advanceMainClockFor(parameter)
- onRoot().captureRoboImage(parameter.filePath, parameter.roborazziOptions)
- }
- )
- ```
- Reference your tester in the Gradle configuration with
- `testerQualifiedClassName = "com.example.MyDesktopPreviewTester"` (the class needs a
- parameterless constructor). If you need to change scanning or file naming as well,
- implement `DesktopComposePreviewTester` by delegating to the default tester and
- override the corresponding method (`testParameters()` / `test()`).
- To wrap each generated test in a JUnit `TestRule` (a `TestWatcher`, retry rule, etc.),
- override `options()` and provide a `testRuleFactory`:
- ```kotlin
- @OptIn(ExperimentalRoborazziApi::class, InternalRoborazziApi::class)
- class MyDesktopPreviewTester : DesktopComposePreviewTester by DefaultDesktopComposePreviewTester() {
- override fun options(): DesktopComposePreviewTester.Options =
- DesktopComposePreviewTester.defaultOptionsFromPlugin.copy(
- testLifecycleOptions = DesktopComposePreviewTester.Options.JUnit4TestLifecycleOptions(
- testRuleFactory = { MyWatcherRule() }
- )
- )
- }
- ```
- Unlike the Robolectric tester there is no compose rule factory: Compose Desktop's test
- harness is function-scoped (`runDesktopComposeUiTest`), not rule-based.
- ### Feature parity with the Android preview support
- | Feature | Android (Robolectric) | Compose Desktop |
- |---|---|---|
- | Generated preview tests | ✅ | ✅ |
- | `packages`, `includePrivatePreviews`, `testerQualifiedClassName`, `generatedTestClassCount` | ✅ | ✅ |
- | `annotationFilter` (`@RoboPreviewInclude` / `@RoboPreviewExclude`) | ✅ | ✅ |
- | `@PreviewParameter` (`PreviewParameterProvider`, one capture per value) | ✅ | ✅ |
- | `@RoboComposePreviewOptions` (`manualClockOptions`, one test per variation) | ✅ | ✅ |
- | Custom JUnit `TestRule` around generated tests (`testRuleFactory`) | ✅ | ✅ |
- | Compose rule factory (`composeRuleFactory`) | ✅ | Not applicable (function-scoped harness) |
- | `@Preview` annotation options (`widthDp`/`heightDp`, `fontScale`, `showBackground`/`backgroundColor`, `locale`, `uiMode` dark bit) | ✅ (see below) | ✅ |
- | `@Preview(device = ...)` | ✅ | Not applicable (no device configuration on desktop) |
- | `robolectricConfig` (device qualifiers, SDK) | ✅ | Not applicable |
- On Compose Desktop the `@Preview` annotation options are applied as follows:
- - `widthDp`/`heightDp`: the preview is wrapped in a fixed-size box (density is `1`, so 1dp equals 1px). When neither is specified the preview still renders wrap-content.
- - `fontScale`: applied through `LocalDensity` (density stays `1`), because `DeviceConfigurationOverride.FontScale` is unsupported on desktop.
- - `showBackground`/`backgroundColor`: draws a background behind the preview, defaulting to white when `showBackground = true` but no color is given.
- - `locale`: sets `java.util.Locale.getDefault()` for the capture and restores it afterwards. Accepts `"ja"`, `"ja-rJP"`, and `"ja-JP"` forms.
- - `uiMode`: only the night bit is honored (dark mode via `LocalSystemTheme`); other configuration bits are ignored.
- - `device`: not applicable, as desktop has no device configuration.
- ## Annotation-based Capture Control
- To enable fine-grained control over screenshot timing in Compose Previews, add the annotations dependency:
- ```gradle
- testImplementation("io.github.takahirom.roborazzi:roborazzi-annotations:[version]")
- ```
- Use `@RoboComposePreviewOptions` to configure time-based captures:
- ```kotlin
- @RoboComposePreviewOptions(
- manualClockOptions = [ManualClockOptions(advanceTimeMillis = 516L)]
- )
- @Preview
- @Composable
- fun DelayedPreview() {
- var visible by remember { mutableStateOf(false) }
- LaunchedEffect(Unit) {
- delay(500)
- visible = true
- }
- if (visible) {
- Text("Content appears after 500ms")
- }
- }
- ```
- This annotation enables capturing screenshots at specific time intervals, particularly useful for testing animated components or delayed state changes.
- ## PreviewWrapper support
- Previews annotated with [`@PreviewWrapper`](https://developer.android.com/reference/kotlin/androidx/compose/ui/tooling/preview/PreviewWrapper) (Compose UI 1.11+) are automatically wrapped by ComposablePreviewScanner 0.9.0 or later, so the wrapper's content, such as a theme or background, appears in the screenshots without any extra setup:
- ```kotlin
- class MyWrapperProvider : PreviewWrapperProvider {
- @Composable
- override fun Wrap(content: @Composable () -> Unit) {
- MyTheme { content() }
- }
- }
- @PreviewWrapper(MyWrapperProvider::class)
- @Preview
- @Composable
- fun WrappedPreview() { ... }
- ```
- ## Manually adding Compose Preview screenshot tests
- Roborazzi provides a helper function for ComposablePreviewScanner.
- You can add the following dependency to your project to use the helper function:
- `testImplementation("io.github.takahirom.roborazzi:roborazzi-compose-preview-scanner-support:[version]")`
- Then you can use the `ComposablePreview<AndroidPreviewInfo>.captureRoboImage()` function to capture the Composable Preview using the settings in Preview annotations.
- To obtain the `ComposablePreview` object, please refer to [ComposablePreviewScanner](https://github.com/sergio-sastre/ComposablePreviewScanner).
- ```kotlin
- fun ComposablePreview<AndroidPreviewInfo>.captureRoboImage(
- filePath: String,
- roborazziOptions: RoborazziOptions
- )
- ```
- ### The supported `@Preview` annotation options
- Currently, we don't support all the annotation options provided by the Compose Preview.
- You can check the supported annotations in the [source code](https://github.com/takahirom/roborazzi/blob/0810ceb7133e6ec38472046cb741242a5ef6ab9e/roborazzi-compose-preview-scanner-support/src/main/java/com/github/takahirom/roborazzi/RoborazziPreviewScannerSupport.kt#L27).
- We are looking forward to your contributions to support more annotation options.
- <!-- end -->
- <!-- topic_ai_powered_image_assertion -->
- <!-- Generated by docs/topics/ai_powered_image_assertion.md. Do not edit this file. -->
- # Experimental AI-Powered Image Assertion
- Roborazzi supports AI-powered image assertion.
- AI-powered image assertion is an experimental feature. Screenshot tests are a great way to verify your app's UI, but verifying the content of the images can be a tedious and time-consuming task. This manual effort reduces scalability. Roborazzi can help automate this process through AI-powered image assertion, making it more efficient and scalable.
- There are two library modules: `io.github.takahirom.roborazzi:roborazzi-ai-gemini` and `io.github.takahirom.roborazzi:roborazzi-ai-openai` for AI-powered image assertion.
- `roborazzi-ai-gemini` leverages [Gemini](https://gemini.google.com/) and [generative-ai-kmp](https://github.com/PatilShreyas/generative-ai-kmp), while `roborazzi-ai-openai` utilizes the [OpenAI API](https://platform.openai.com/) through raw HTTP API calls implemented with Ktor and KotlinX Serialization
- ```kotlin
- ...
- @get:Rule
- val composeTestRule = createAndroidComposeRule<MainActivity>()
- @get:Rule
- val roborazziRule = RoborazziRule(
- options = RoborazziRule.Options(
- roborazziOptions = RoborazziOptions(
- compareOptions = RoborazziOptions.CompareOptions(
- aiAssertionOptions = AiAssertionOptions(
- aiAssertionModel = GeminiAiAssertionModel(
- // DO NOT HARDCODE your API key in your code.
- // This is an example passing API Key through unitTests.all{ environment(key, value) }
- apiKey = System.getenv("gemini_api_key") ?: ""
- ),
- )
- )
- )
- )
- )
- @Test
- fun captureWithAi() {
- ROBORAZZI_DEBUG = true
- onView(ViewMatchers.isRoot())
- .captureRoboImage(
- roborazziOptions = provideRoborazziContext().options.addedAiAssertions(
- AiAssertionOptions.AiAssertion(
- assertionPrompt = "it should have PREVIOUS button",
- requiredFulfillmentPercent = 90,
- ),
- AiAssertionOptions.AiAssertion(
- assertionPrompt = "it should show First Fragment",
- requiredFulfillmentPercent = 90,
- )
- )
- )
- }
- ```
- ## Behavior of AI-Powered Image Assertion
- AI-Powered Image Assertion runs only when the images are different. If the images are the same, AI-Powered Image Assertion is skipped.
- This is because AI-Powered Image Assertion can be slow and expensive.
- ## Manual Image Assertion
- You can use manual image assertion with Roborazzi. This allows you to utilize local LLMs or other LLMs. Manual Image Assertion doesn't require adding any dependencies other than Roborazzi itself.
- You must provide the `AiAssertionModel` to `RoborazziOptions` to use manual image assertion.
- ```kotlin
- interface AiAssertionModel {
- fun assert(
- referenceImageFilePath: String,
- comparisonImageFilePath: String,
- actualImageFilePath: String,
- aiAssertionOptions: AiAssertionOptions
- ): AiAssertionResults
- fun assert(
- targetImages: TargetImages,
- aiAssertionOptions: AiAssertionOptions
- ): AiAssertionResults
- }
- ```
- ```kotlin
- compareOptions = RoborazziOptions.CompareOptions(
- aiAssertionOptions = AiAssertionOptions(
- aiAssertionModel = object : AiAssertionOptions.AiAssertionModel {
- override fun assert(
- referenceImageFilePath: String,
- comparisonImageFilePath: String,
- actualImageFilePath: String,
- aiAssertionOptions: AiAssertionOptions
- ): AiAssertionResults {
- // You can use any LLMs here to create AiAssertionResults
- return AiAssertionResults(
- aiAssertionResults = aiAssertionOptions.aiAssertions.map { assertion ->
- AiAssertionResult(
- assertionPrompt = assertion.assertionPrompt,
- fulfillmentPercent = 100,
- requiredFulfillmentPercent = assertion.requiredFulfillmentPercent,
- failIfNotFulfilled = assertion.failIfNotFulfilled,
- explanation = "This is a manual test.",
- )
- }
- )
- }
- override fun assert(
- targetImages: TargetImages,
- aiAssertionOptions: AiAssertionOptions
- ): AiAssertionResults {
- // targetImages.images holds the images to assert (e.g. targetImages.images.first().filePath)
- return AiAssertionResults(
- aiAssertionResults = aiAssertionOptions.aiAssertions.map { assertion ->
- AiAssertionResult(
- assertionPrompt = assertion.assertionPrompt,
- fulfillmentPercent = 100,
- requiredFulfillmentPercent = assertion.requiredFulfillmentPercent,
- failIfNotFulfilled = assertion.failIfNotFulfilled,
- explanation = "This is a manual test.",
- )
- }
- )
- }
- },
- aiAssertions = listOf(
- AiAssertionOptions.AiAssertion(
- assertionPrompt = "it should have PREVIOUS button",
- requiredFulfillmentPercent = 90,
- ),
- ),
- )
- )
- ...
- ```
- <!-- end -->
- <!-- topic_idea_plugin -->
- <!-- Generated by docs/topics/idea_plugin.md. Do not edit this file. -->
- # Roborazzi IntelliJ IDEA and Android Studio Plugin
- [https://plugins.jetbrains.com/plugin/24561-roborazzi](https://plugins.jetbrains.com/plugin/24561-roborazzi)
- Demo of Roborazzi IntelliJ IDEA and Android Studio Plugin.
- [https://github.com/takahirom/roborazzi/assets/1386930/bd3e8106-1971-4ec4-b764-3f1831999228](https://github.com/takahirom/roborazzi/assets/1386930/bd3e8106-1971-4ec4-b764-3f1831999228)
- The Roborazzi plugin enhances your development workflow by automatically displaying screenshots related to Roborazzi's screenshot tests within IntelliJ IDEA. Easily view and verify visual outputs directly in your IDE, streamlining your testing and development process.
- <!-- end -->
- <!-- topic_compose_multiplatform -->
- <!-- Generated by docs/topics/compose_multiplatform.md. Do not edit this file. -->
- # Multiplatform support
- ## Experimental feature: iOS support
- Roborazzi supports Compose Multiplatform iOS. You can use Roborazzi with Compose iOS as follows:
- Gradle settings
- ```kotlin
- plugins {
- kotlin("multiplatform")
- id("org.jetbrains.compose")
- id("io.github.takahirom.roborazzi")
- }
- kotlin {
- sourceSets {
- ...
- val appleTest by getting {
- dependencies {
- implementation("io.github.takahirom.roborazzi:roborazzi-compose-ios:[version]") // Use 1.13.0 or higher
- implementation(kotlin("test"))
- }
- }
- ...
- ```
- Test with Roborazzi
- ```kotlin
- class IosTest {
- @OptIn(ExperimentalTestApi::class)
- @Test
- fun test() {
- runComposeUiTest {
- setContent {
- MaterialTheme {
- Column {
- Button(onClick = { }) {
- Text("Hello World")
- }
- Box(
- modifier = Modifier
- .background(Color.Red.copy(alpha = 0.5f), MaterialTheme.shapes.small)
- .size(100.dp),
- )
- }
- }
- }
- // iOS uses the same RoborazziOptions as the other targets. For example,
- // allow up to 1% of pixels to differ before a comparison fails.
- val roborazziOptions = RoborazziOptions(
- compareOptions = RoborazziOptions.CompareOptions(changeThreshold = 0.01F),
- )
- // Unlike the JVM, iOS has no automatic file-name generation, so filePath
- // is required for every capture.
- onRoot().captureRoboImage(this, filePath = "ios.png", roborazziOptions = roborazziOptions)
- onNodeWithText("Hello World").captureRoboImage(
- this,
- filePath = "ios_button.png",
- roborazziOptions = roborazziOptions,
- )
- }
- }
- }
- ```
- Then, you can run the Gradle tasks for iOS Support, just like you do for Android Support.
- ```
- ./gradlew recordRoborazzi[SourceSet]
- ```
- ```
- ./gradlew recordRoborazziIosSimulatorArm64
- ./gradlew compareRoborazziIosSimulatorArm64
- ./gradlew verifyRoborazziIosSimulatorArm64
- ...
- ```
- The currently implemented features for iOS support are as follows:
- | Feature | status |
- |---|---|
- | Record | supported |
- | Compare | supported |
- | Verify | supported |
- | Report | supported |
- | Dropbox/Differ comparison | supported |
- | threshold / resultValidator | supported |
- | diffPercentage | supported |
- | resizing image (resizeScale) | supported |
- | context data | supported (user-supplied only; the automatically-added default context data such as the test class name is JVM-only) |
- | custom reporter | supported |
- | ComparisonStyle | supported (Simple and Grid; Grid falls back to Simple when the density is unavailable) |
- | RoborazziRecordFilePathStrategy | 🆖 (filePath is required; a relative path always resolves against the output directory) |
- | automatic file naming | 🆖 (filePath is required) |
- | image format | PNG only (WebP encoding is not supported on iOS) |
- | pixelBitConfig | 🆖 (Rgb565 falls back to Argb8888 with a warning; CoreGraphics has no 5-6-5 format) |
- | dump | n/a (Robolectric-only concept) |
- | applyDeviceCrop | n/a (Robolectric-only concept) |
- | UI tree dump JSON sidecar (`uiTreeDumpOptions`) | supported (record writes `MyTest.uitree.json` next to the golden; compare/verify writes `MyTest_actual.uitree.json` in the compare output directory — the same `_actual` basename contract as the other platforms) |
- | UI tree annotated image (`annotateImage`) | supported (drawn with UIKit/CoreGraphics; `MyTest.annotated.png` / `MyTest_actual.annotated.png`, matching the Android/Desktop look) |
- > **Note on translucent pixels:** the iOS canvas stores pixels premultiplied (a CoreGraphics constraint), so translucent colors lose precision proportional to `255 / alpha` (opaque pixels are lossless). The loss is deterministic, so comparing identically-produced images is unaffected; only cross-source comparisons of low-alpha content may need a small threshold.
- iOS runs on the same shared pipeline as the JVM and Compose Desktop targets
- (`RoborazziOptions` → `processOutputImageAndReport` → `RoboCanvas`), so the image
- comparator, threshold / `resultValidator`, `resizeScale`, context data, custom
- reporters, and the `reference | diff | new` comparison output (including
- `ComparisonStyle.Grid`) all behave the same way. A few platform-specific
- features remain unsupported (see the table above); contributions are welcome.
- ## Experimental feature: Compose Desktop support
- Roborazzi supports Compose Desktop. You can use Roborazzi with Compose Desktop as follows:
- Gradle settings
- ```kotlin
- plugins {
- kotlin("multiplatform")
- id("org.jetbrains.compose")
- id("io.github.takahirom.roborazzi")
- }
- kotlin {
- // You can use your source set name
- jvm("desktop")
- sourceSets {
- ...
- val desktopTest by getting {
- dependencies {
- implementation("io.github.takahirom.roborazzi:roborazzi-compose-desktop:[version]") // Use 1.6.0-alpha-2 or higher
- implementation(kotlin("test"))
- }
- }
- ...
- ```
- Test target Composable function
- ```kotlin
- @Composable
- fun App() {
- var text by remember { mutableStateOf("Hello, World!") }
- MaterialTheme {
- Button(
- modifier = Modifier.testTag("button"),
- onClick = {
- text = "Hello, Desktop!"
- }) {
- Text(
- style = MaterialTheme.typography.h2,
- text = text
- )
- }
- }
- }
- ```
- Test with Roborazzi
- ```kotlin
- class MainKmpTest {
- @OptIn(ExperimentalTestApi::class)
- @Test
- fun test() = runDesktopComposeUiTest {
- setContent {
- App()
- }
- val roborazziOptions = RoborazziOptions(
- recordOptions = RoborazziOptions.RecordOptions(
- resizeScale = 0.5
- ),
- compareOptions = RoborazziOptions.CompareOptions(
- changeThreshold = 0F
- )
- )
- onRoot().captureRoboImage(roborazziOptions = roborazziOptions)
- onNodeWithTag("button").performClick()
- onRoot().captureRoboImage(roborazziOptions = roborazziOptions)
- }
- }
- ```
- Then, you can run the Gradle tasks for Desktop Support, just like you do for Android Support.
- ```
- ./gradlew recordRoborazzi[SourceSet]
- ```
- ```
- ./gradlew recordRoborazziDesktop
- ./gradlew compareRoborazziDesktop
- ./gradlew verifyRoborazziDesktop
- ...
- ```
- If you use the Kotlin JVM plugin, the task will be `recordRoborazzi**Jvm**`.
- Compose Desktop has **full [UI tree dump](https://takahirom.github.io/roborazzi/ui-tree-dump.html)
- support**: enabling `uiTreeDumpOptions` (or `-Proborazzi.dumpUiTree=true`) on a
- `SemanticsNodeInteraction.captureRoboImage` writes both the `MyTest.uitree.json`
- sidecar and (by default) the annotated `MyTest.annotated.png`, with the same
- naming and `_actual` basename semantics as Android.
- The sample image
- 
- 
- <!-- end -->
- <!-- topic_gradle_properties_options -->
- <!-- Generated by docs/topics/gradle_properties_options.md. Do not edit this file. -->
- # Roborazzi gradle.properties Options and Recommendations
- You can configure the following options in your `gradle.properties` file.
- You can also use `-P` to set the options in the command line. For example, `./gradlew test -Proborazzi.test.record=true`.
- ## roborazzi.test
- This option enables you to configure the behavior of Roborazzi. By default, all settings are set to false.
Lines 2,001–2,236 are not shown. The link to the file on GitHub has every line.
Ratings and comments
Sign in to rate this skill.
Sign inFree to use. If it’s helped, pass it on.